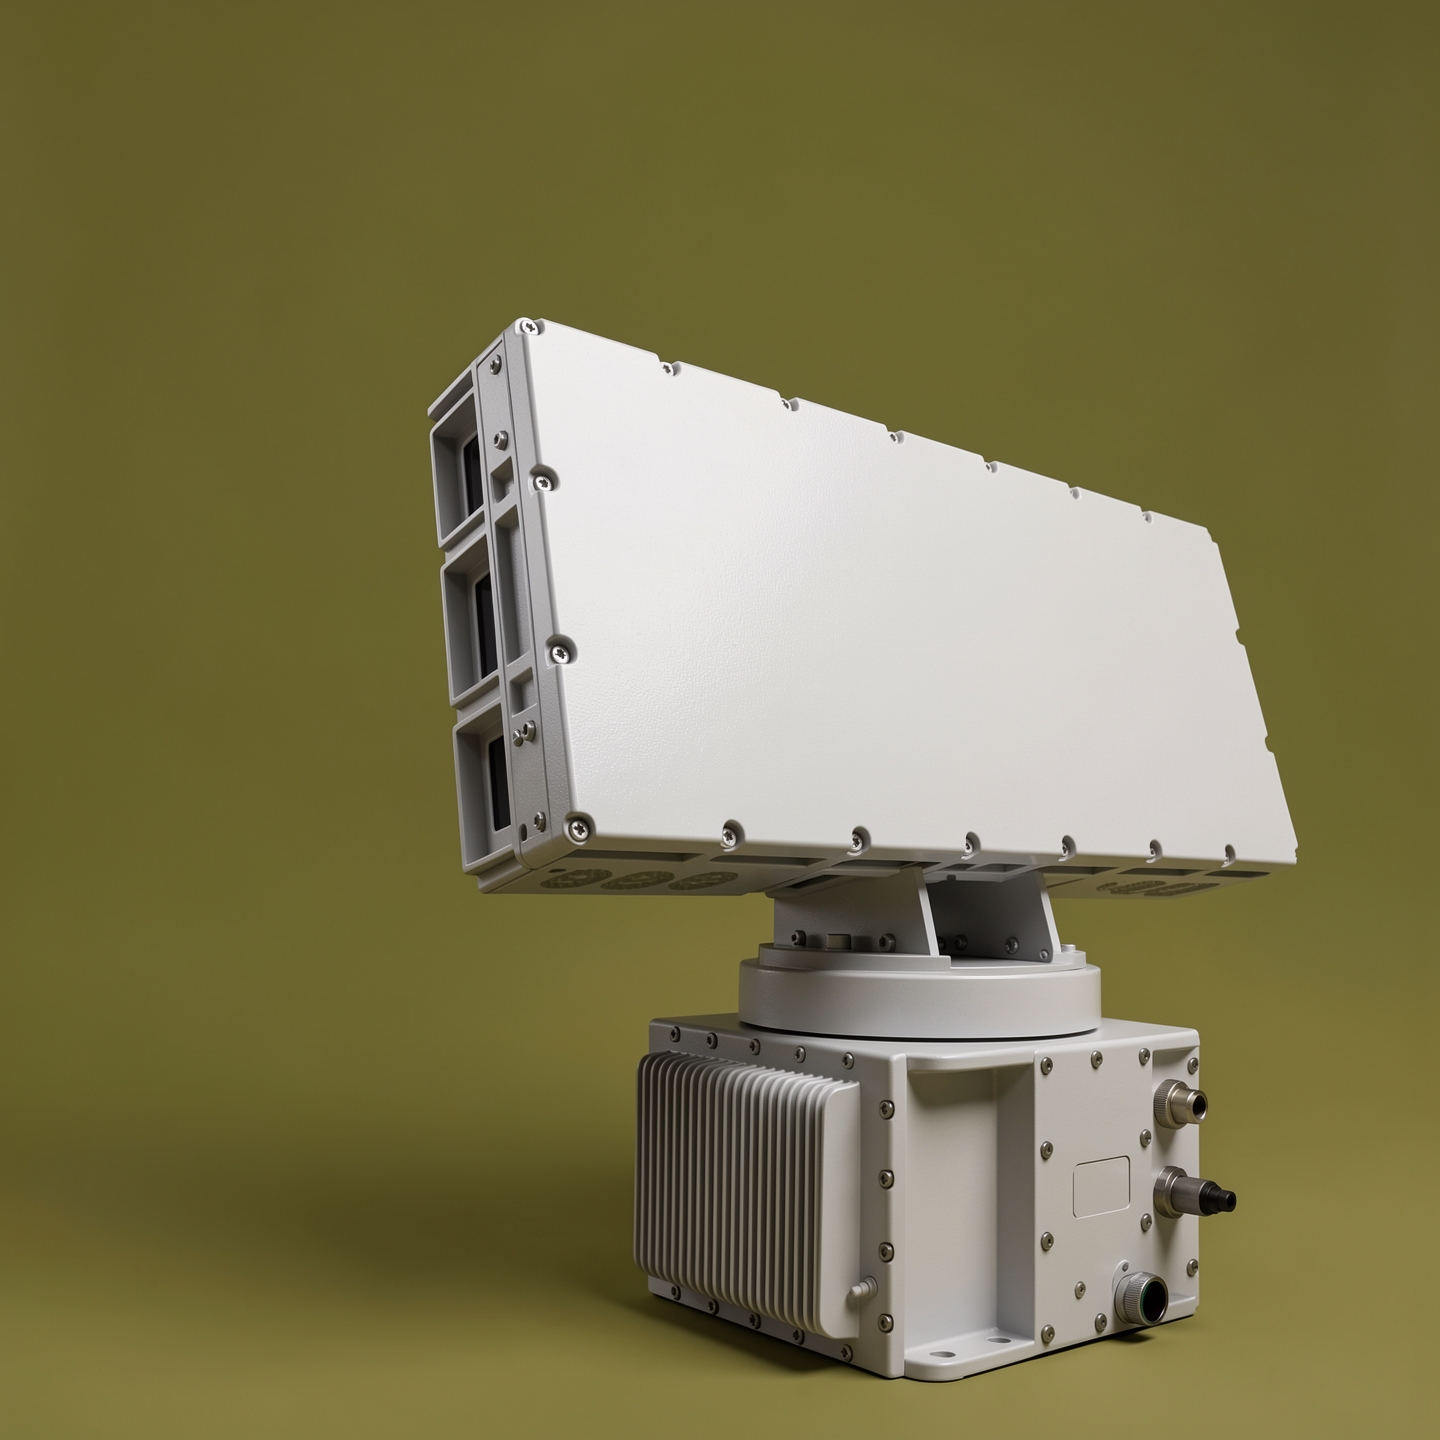
Description
The AGT-3D-RD6000KU radar employs an advanced one-dimensional simultaneous multi-beam system based on Digital Beam Forming (DBF) technology. It is capable of detecting a wide variety of low-altitude aircraft and objects including multi-rotor UAVs, fixed-wing UAVs, cruisers, swarms, hot air balloons, airships, power parachutes, and bionic birds. The system obtains real-time target position data such as distance, azimuth, pitch, longitude, latitude, and height, along with motion posture, echo intensity, RCS, and target type classification. An input interface protocol is reserved to support remote control or radar network integration.
Overview
- Ku-band low-altitude surveillance radar with DBF-based one-dimensional simultaneous multi-beam architecture
- Pitch multiple beams at the same time with azimuth mechanical scanning
- Real-time detection and tracking of low-altitude aircraft and objects
- Outputs target position, motion posture, echo intensity, RCS, and target type
- Supports remote control and radar network construction via reserved protocol interface
Applications
- Airport bird deterrence and wildlife hazard management
- Low-altitude UAV detection and counter-UAS systems
- Perimeter and critical infrastructure airspace surveillance
- Airship, hot air balloon, and ultralight aircraft monitoring
- Radar network and integrated air defense applications
Technical specification
| Tracking |
|---|
| Beam scanning method |
Pitch multiple beams simultaneously, azimuth mechanical scanning |
| Detection |
|---|
| Detection distance |
<5km |
| Speed measurement range (radial) |
1m/s ~ 150m/s |
| Storage temperature range |
-45℃ ~ 65℃ |
| Working temperature range |
-40℃ ~ 65℃ |
| Power |
|---|
| Weight |
≤50kg |
| Environment |
|---|
| Maximum working humidity |
95%@40℃ |
| Interface |
|---|
| Communication transmission protocol |
UDP |